ODM Program · Our Story
Two SLAM engineers' conviction: every VLA startup deserves affordable data terminals
🎓 Our Team
Our two co-founders come from NUAA (Nanjing University of Aeronautics and Astronautics) and SJTU (Shanghai Jiao Tong University), both long-time SLAM researchers in multi-sensor fusion, hardware-level synchronization and spatiotemporal alignment.
We know the first barrier for embodied VLA from pretraining to deployment is not algorithms — it's high-quality, multimodal, time-synchronized first-person data.
- NUAA · Co-founder — SLAM & multi-sensor fusion, system architecture
- SJTU · Co-founder — visual-inertial odometry & hardware sync, capture pipeline
- Shared belief — serve scene owners, help VLA teams deploy for real
💡 The Industry Problem We See
Every VLA startup struggles with funding: angel rounds of a few million RMB. To amass 1,000 EGO devices and 1 million hours of vertical pretraining data, buying terminals at ¥5,000–10,000 each simply doesn't add up —
The money ends up with speculators selling overpriced hardware at the peak and leaving, while real data teams struggle.
- Pain — expensive terminals, closed sync solutions, incompatible formats
- Malpractice — overpricing, hit-and-run vendors, no after-sales
- Our stance — long-term builders, not speculators
🚀 Our Advantages
Our hardware-software-algorithm DNA gives every EGO capture terminal ground-truth-level data capability:
- Annotation-free pretraining data — body pose / hand joint pose captured at sub-millimeter ground truth accuracy, meaning no online annotation needed
- Easy HW integration of any third-party gloves/EMG bands — EGO-Hub provides hardware external-trigger synchronized sampling for any third-party glove / wristband sensor
🎯 Our Decision
We are opening our ODM program right now: full schematics, source files and technical support — pushing the BOM of a 4-6 camera terminal below ¥1,000 — to squeeze out speculators and help VLA startups grow healthily.
ODM Program quote on request · 4-cam BOM <¥1,000 · 6-8 cam (incl. wrist cameras & sensor fusion) BOM <¥1,500🛒 Ego MK3 · Stereo Quick-Ship
Highlights
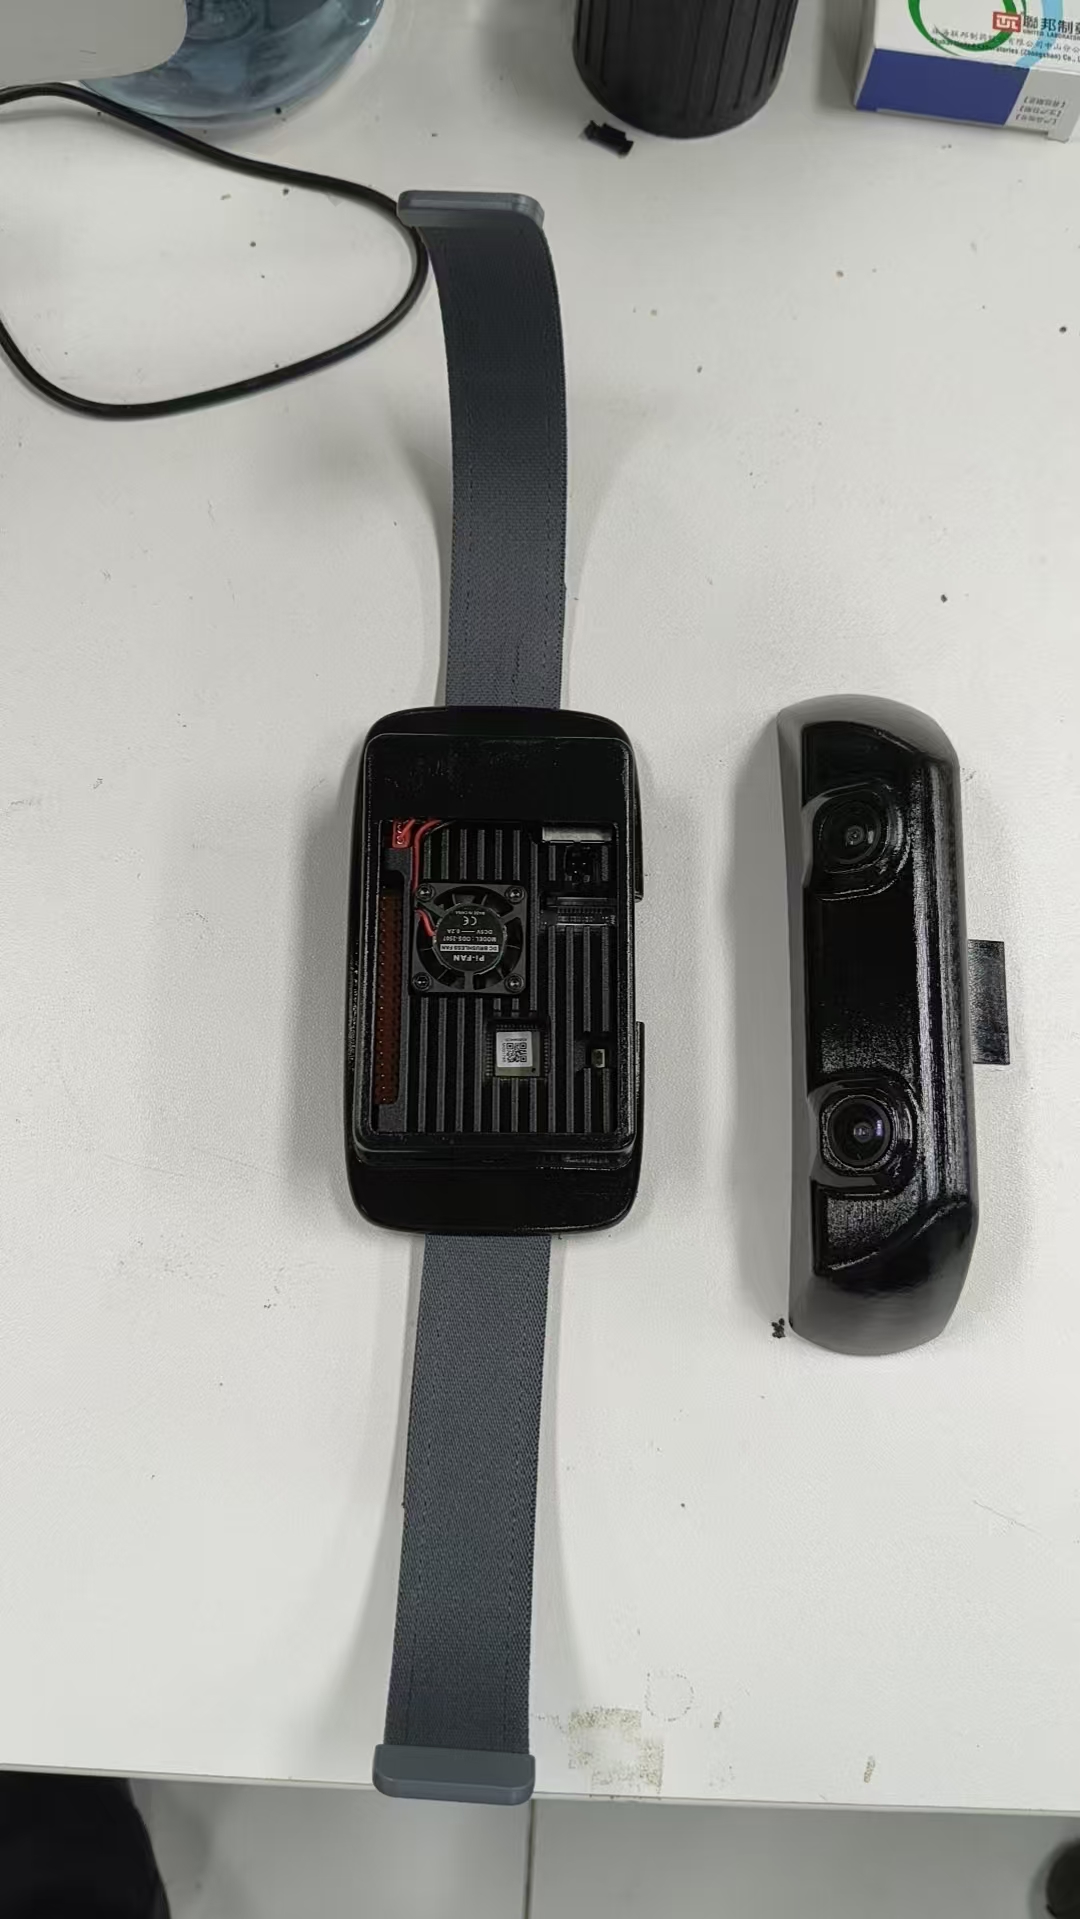
- Dual global-shutter UVC module, plug & play
- RK1126B SoC · 3 TOPS edge NPU (INT8), lightweight VIO / detection realtime
- 2GB LPDDR4X + 8GB eMMC + microSD (UHS-I)
- WiFi 6 + BT 5.4 + Gigabit Ethernet (PoE)
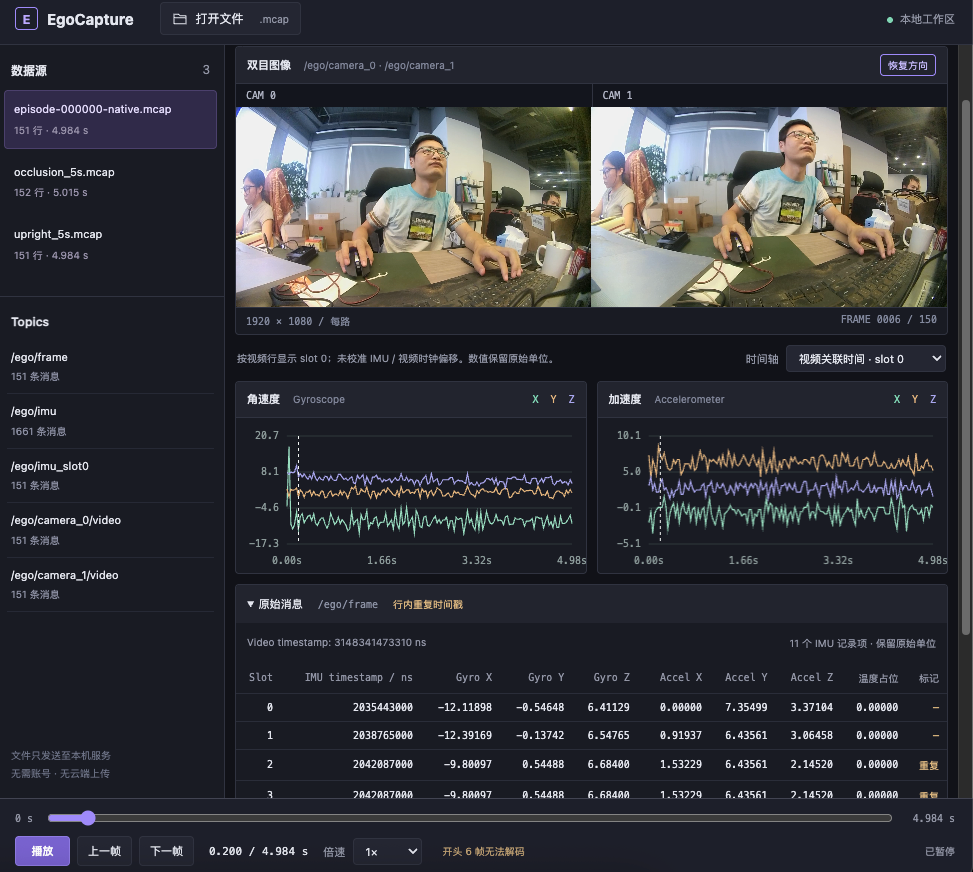
- LeRobot v3.0 output, VLA-ready
- Middleware preinstalled
What's in the box
| Unit | MK3 host + dual camera module |
| System | Ubuntu 22.04 + Ego SDK |
| Data | LeRobot v3.0 output |
| Support | Docs + after-sales |
📋 MK4 4-Cam Hardware & Firmware
Highlights
- Full HW package: schematic / 8-layer PCB / BOM / Gerber
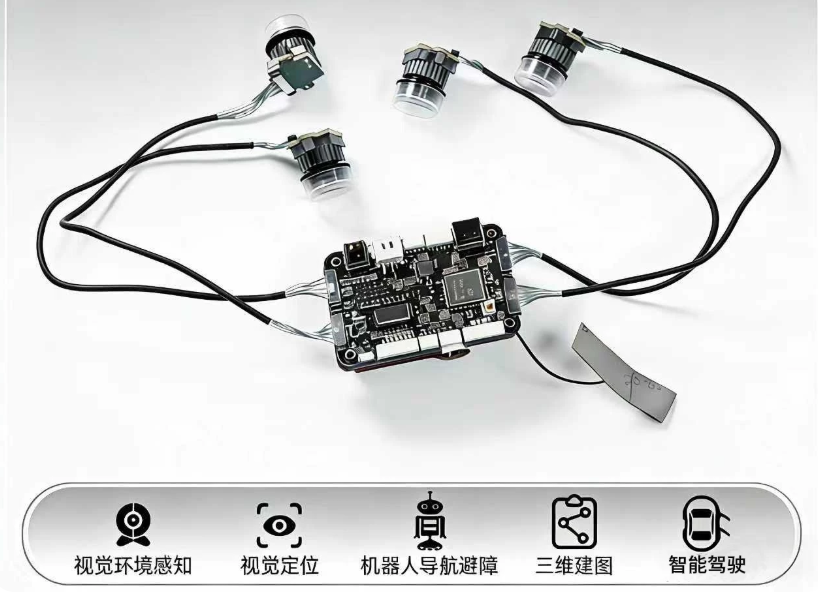
- BSP & driver source: 4×MIPI / SPI / I²C / I²S
- Firmware image + middleware (closed-source, SDK/API)
- External-MCU frame sync + source
- Calibration SOP + tooling
- LeRobot v3.0 output + converter
Deliverables
| HW docs | Production-ready schematics/PCB/BOM |
| Firmware | Image + middleware (closed app layer) |
| Calibration | Intrinsic/extrinsic SOP + tooling |
| Support | Docs + long-term support |
🏭 MK4 4-Cam + Enclosure Tooling
Highlights
- Everything in Plan 2
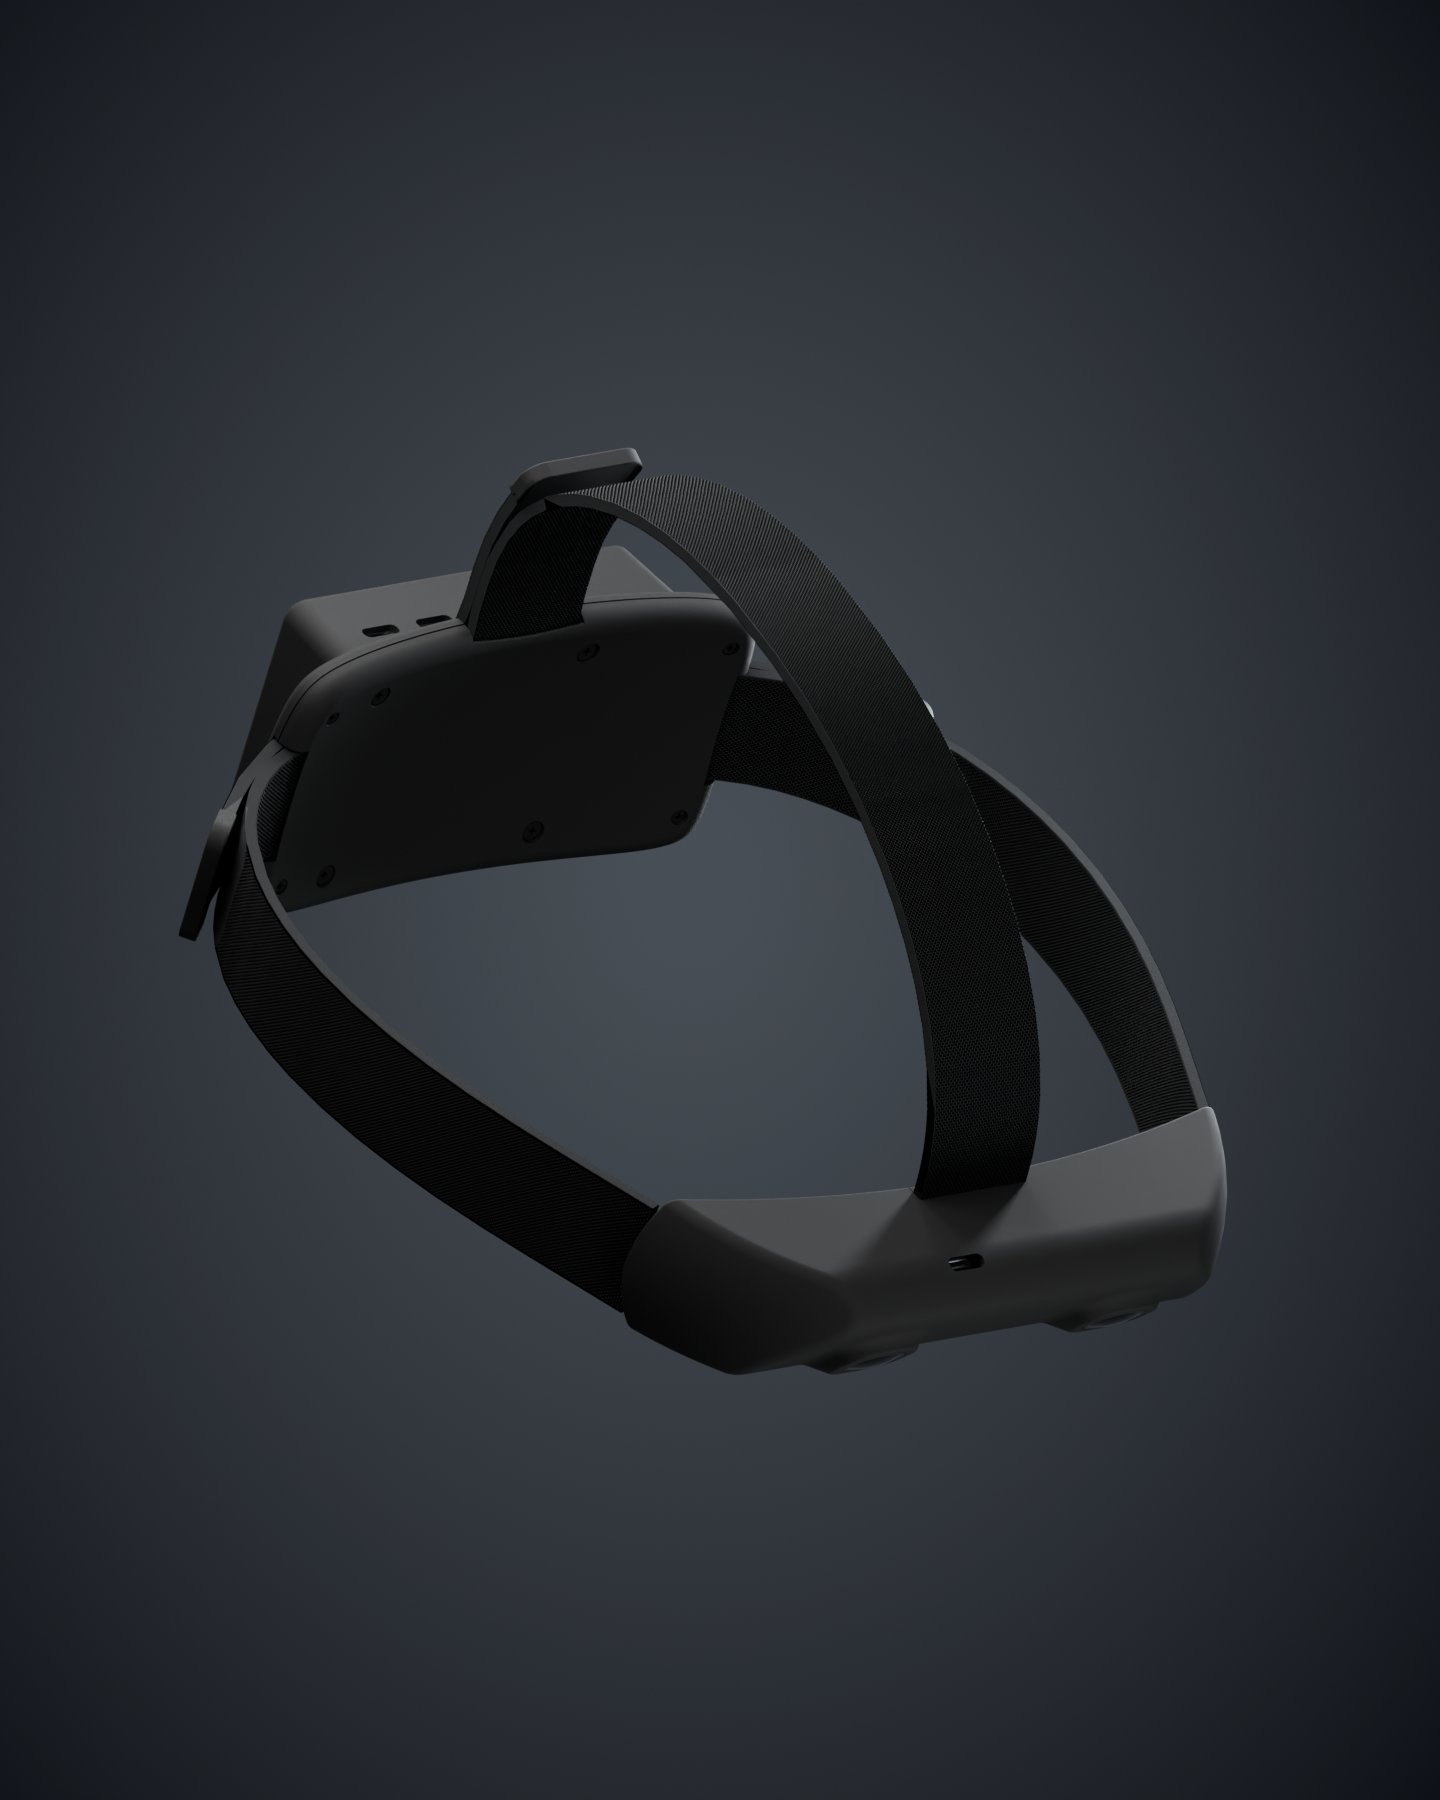
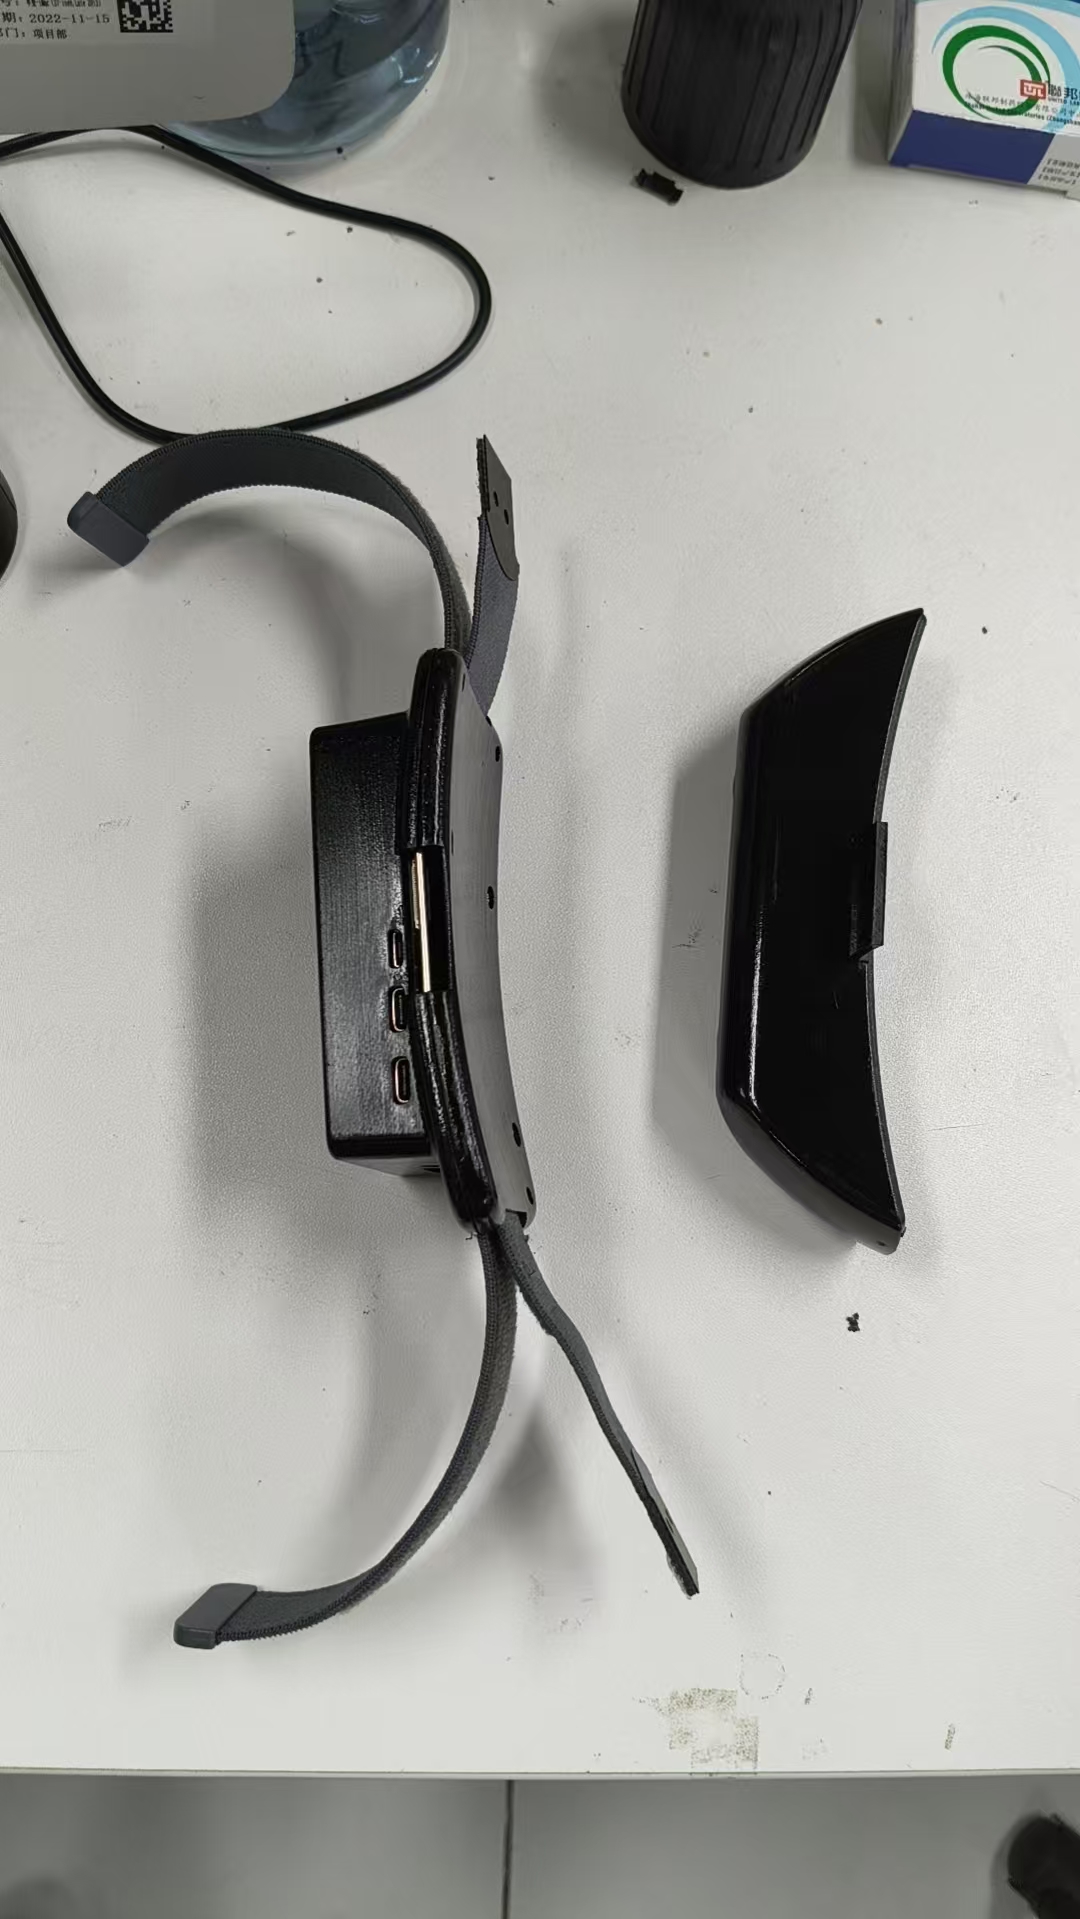
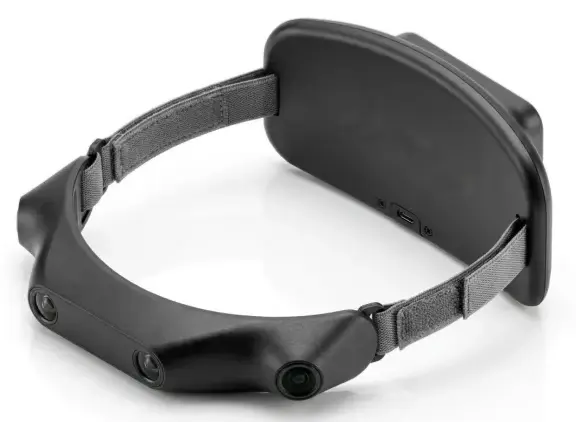
- Full enclosure CAD: forehead / nape / strap (STEP)
- Al-Mg alloy inner frame (drift suppression)
- Private-mold license (injection / CNC)
- ID/CMF design
- App-layer firmware open-source
Deliverables
| HW docs | All of Plan 2 (open app layer) |
| Enclosure | CAD + Al-Mg frame + mold license |
| Support | Docs + long-term support |
🎛 4 Forehead + 2 Wrist · Full Docs
Highlights
- Forehead 4 GS cams (2K RGB ×2 + 720p gray ×2) + wrist 2 × 2K RGB
- Fusion bridge: 6×MIPI to host + source
- Wrist module design (2 cam + band) + source
- Enclosure full set + Al-Mg inner frame
- Private-mold license + ID/CMF
- App-layer firmware open-source
Deliverables
| HW docs | Schematic/PCB/BOM/Gerber (incl. fusion bridge design) |
| Wrist | 2-cam module + band integration |
| Enclosure | CAD + inner frame + mold license |
| Support | Docs + long-term support |
🏆 6 Forehead + 2 Wrist · Full Docs
Highlights
- Forehead 6 GS cams (2K RGB ×2 + 720p gray ×4) + wrist 2 × 2K RGB
- fusion bridge board: multi-input → HW fusion → unified output to host; incl. fusion logic source
- hardware sync bus sync (≤1µs / ±50ns target) + IMU 400Hz HW timestamps
- Wrist module + full enclosure + Al-Mg inner frame
- FPC / MIPI coax harness
- App-layer firmware open-source
Deliverables
| HW docs | Schematic/PCB/BOM/Gerber (incl. fusion bridge board) |
| Fusion logic | fusion logic source + firmware image |
| Harness | FPC ×8 + MIPI coax ×4 |
| Support | Docs + long-term support |
🧤 6 Forehead (w/ IMU) + 2 Wrist + Pose-Tactile Gloves · Full Docs
Highlights
- Forehead 6 GS cams (2K RGB ×2 + 720p gray ×4, with IMU) via fusion bridge board + wrist 2 × 2K RGB
- Integrated EMF pose-tactile gloves or customer-specified multimodal gloves
- Hardware-synced sampling of vision + IMU + glove sensors (unified hardware sync bus timestamps)
- fusion bridge board: multi-input → HW fusion → unified output to host; incl. fusion logic source
- Wrist multimodal module (2 cams + glove sensors + band) + source code
- Full enclosure + Al-Mg inner frame + mold license + ID/CMF
- App-layer firmware open-source + long-term support
Deliverables
| HW docs | Schematic/PCB/BOM/Gerber (incl. fusion bridge board) |
| Fusion logic | fusion logic source + firmware image + HW sync bus |
| Glove integration | Multimodal glove integration (EMF or customer-specified): SPI driver + MANO mapping firmware |
| Wrist module | 2 cams + glove sensors + band (incl. source) |
| HW sync | Unified trigger/timestamps for vision + IMU + gloves |
| Harness | FPC ×8 + MIPI coax ×4 |
| Enclosure | Forehead/rear/headband STEP + Al-Mg inner frame |
| Mold license | Injection/CNC mold authorization + ID/CMF |
| Firmware | App-layer open-source |
| Calibration | Intrinsic/extrinsic SOP + fixture list |
| Support | Docs + long-term support |